CNC Machining for Robotics Parts
Custom metal and plastic components for humanoid, industrial, collaborative, and mobile robots. Weldo supports prototypes, pilot builds, and repeat orders with drawing-based machining and inspection planning.
- Prototype to Production
- Metals & Plastics
- Precision Interface Review
Custom Components for Robotic Systems
Structural, motion, and interface parts made to specified datums, fits, and assembly requirements.
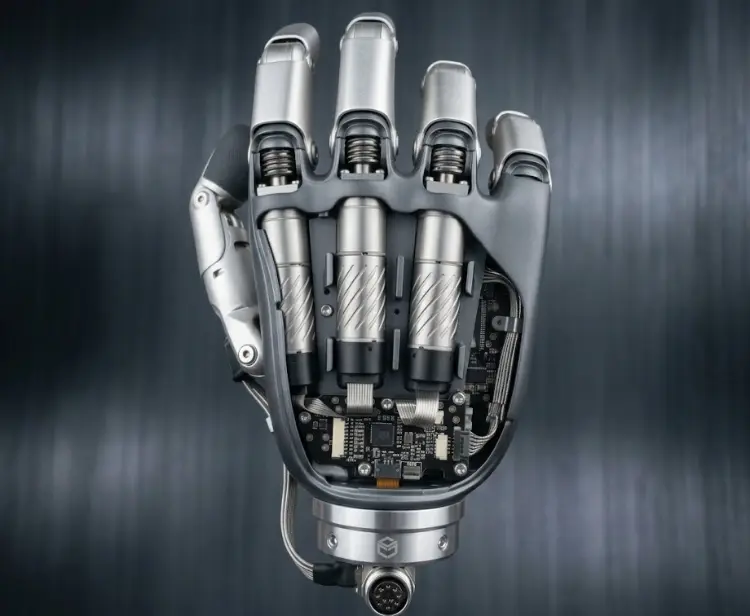
Joint Housings
Motor, bearing, gearbox, and encoder interfaces.
Arms & Structural Links
Lightweight links, multi-face parts, and frames.
End-Effectors & Grippers
Fingers, jaws, tool plates, and handling fixtures.
Shafts & Couplings
Transmission and actuator connection parts.
Gearbox Interfaces
Bearing seats, flanges, covers, and mounting plates.
Sensor Mounts
Camera, encoder, force-sensor, and cable interfaces.
AMR & AGV Hardware
Wheel hubs, chassis brackets, and mounting hardware.
Spacers & Fixtures
Locators, guides, covers, and assembly or test tooling.
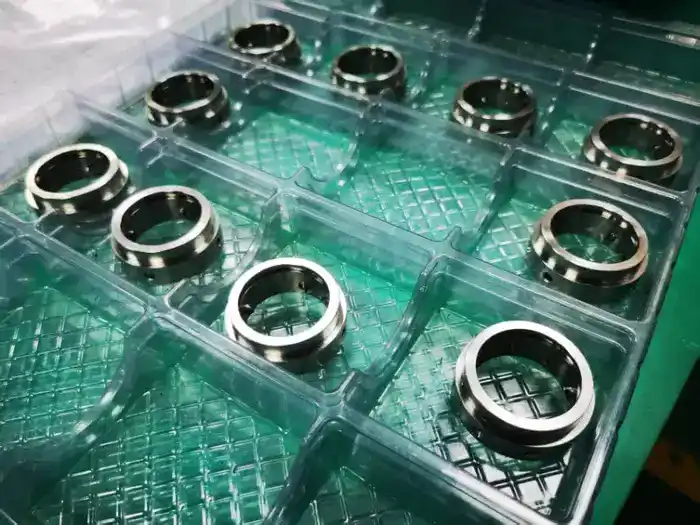
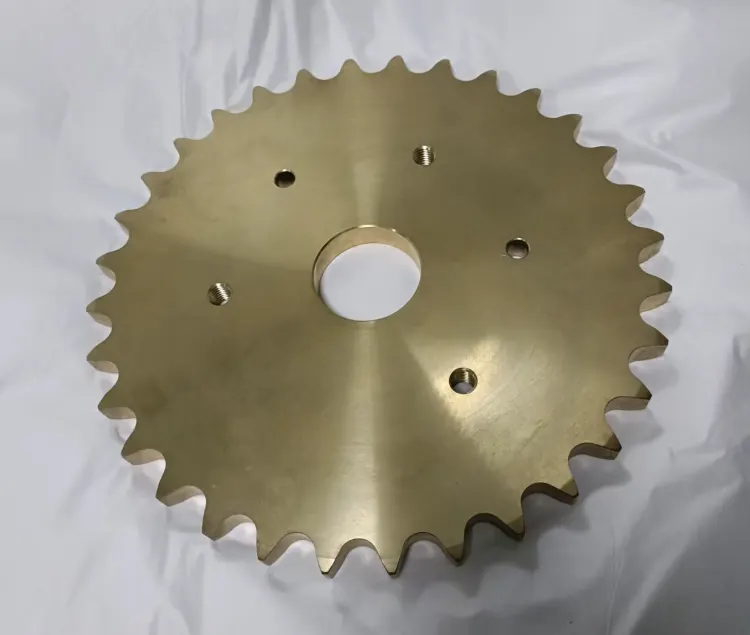
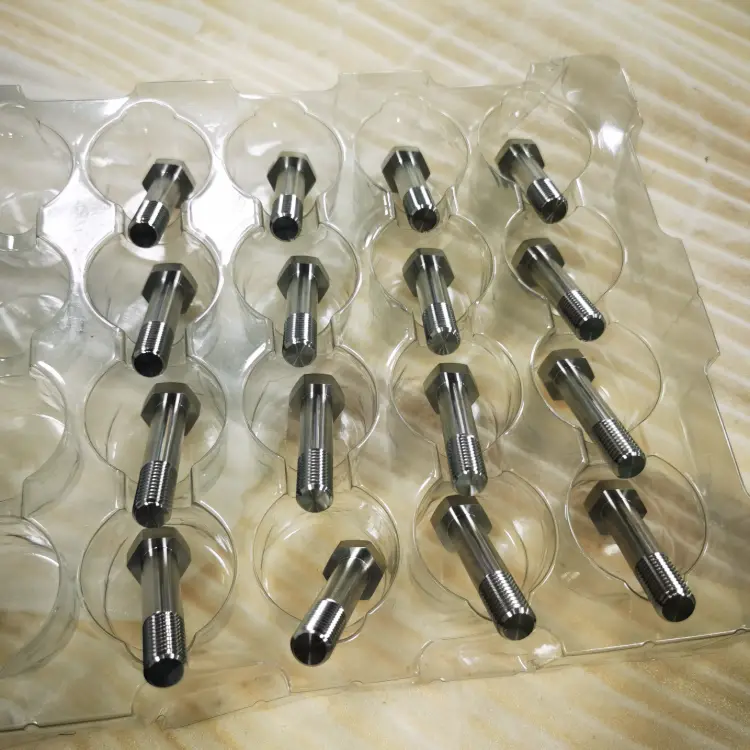
Weldo Robotics Machining Projects
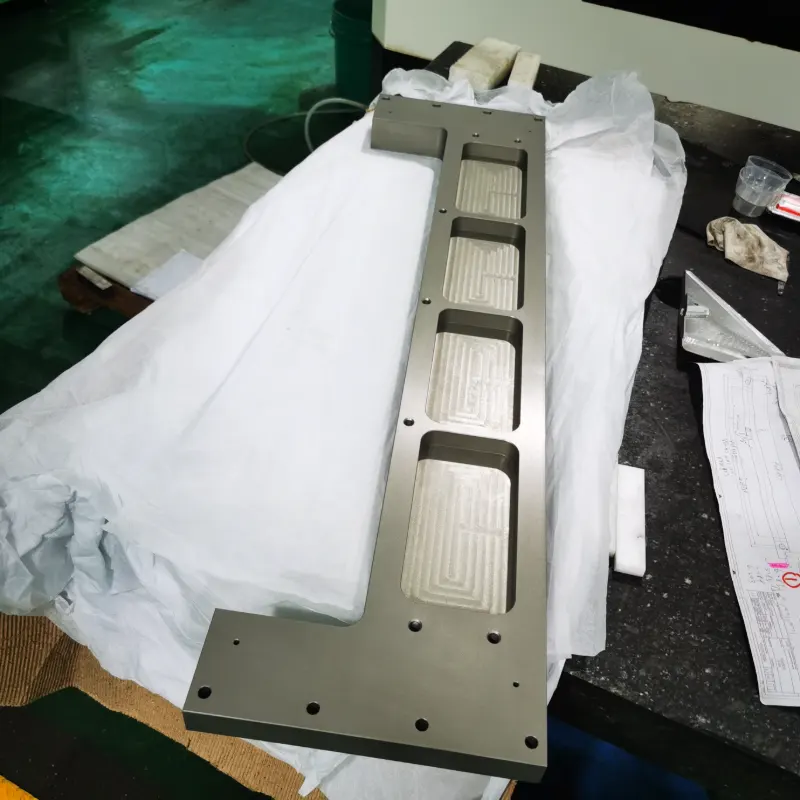
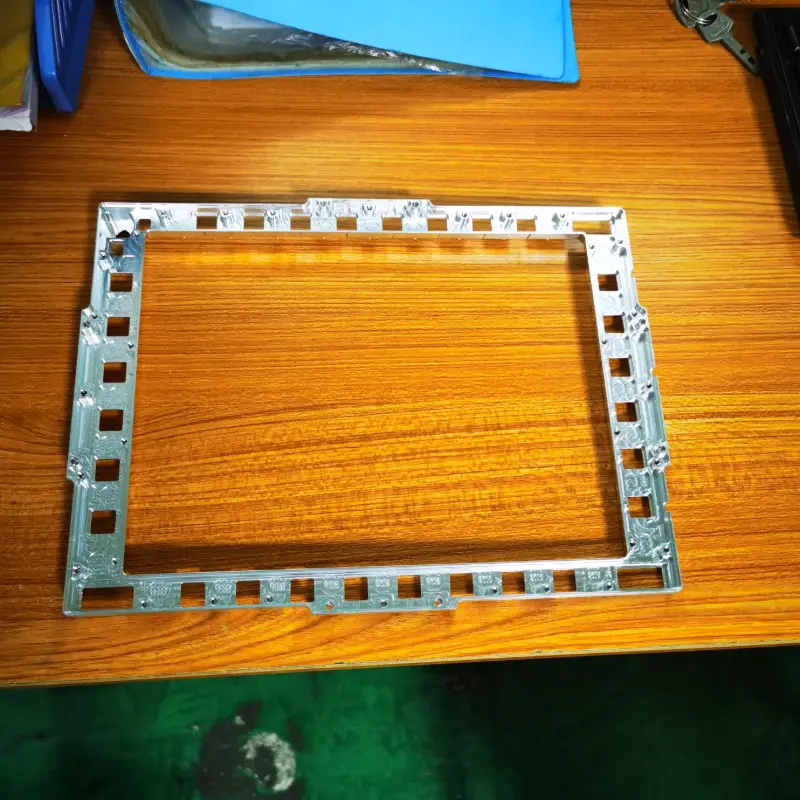
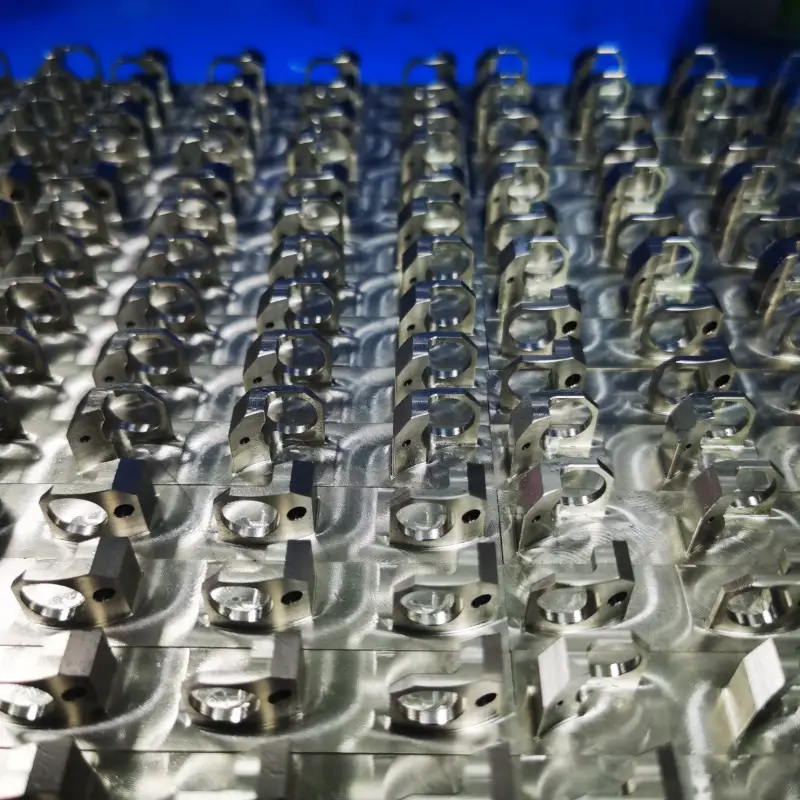
Representative components for robotic motion, structures, tooling, and assembly interfaces.
From CAD Review to Repeat Production
Maintain drawing control while testing fit and motion, approving revisions, and moving from development parts to repeat builds.
DFM Review
Review geometry, functional datums, material, tolerances, and tool access before machining.
Functional Prototypes
Produce drawing-defined parts for customer fit, motion, load, and assembly testing.
Pilot Builds
Support small batches with agreed inspection records and feedback from assembly.
Repeat Production
Release the approved revision with defined manufacturing, inspection, and delivery requirements.
Control the Interfaces That Define Robot Performance
Plan datums, fits, surfaces, and inspection around the assembled mechanism rather than applying one tight tolerance to every feature.
Bearing & Shaft Fits
Define diameters, form, runout, and mating-fit requirements against the drawing.
Motor & Gearbox Datums
Relate pilots, bores, bolt patterns, and mounting faces to functional references.
Thin-Wall Structures
Plan stock, support, clamping, and cutting sequence to limit distortion.
Wear & Sliding Surfaces
Match material, roughness, clearance, and finish to load, motion, and lubrication.
Sensor Interfaces
Control locating faces, cable access, and specified alignment relationships.
Inspection Strategy
Agree critical dimensions, measurement conditions, sampling, and report requirements.
Match Material and Finish to Robot Function
Selections follow the drawing, load, weight, wear, electrical behavior, environment, and production requirements.
Materials for Robotic Components
AluminumLightweight structures and housings.
6061, 6082, 7075, and 5083 are common starting points for arms, links, housings, and tooling plates. Confirm temper, loads, stiffness, corrosion, and finishing allowance.
Explore Material Options →Alloy SteelLoaded transmission and wear interfaces.
4140, 4340, and specified tool steels suit selected shafts, pins, gears, and tooling. Define heat-treatment condition, hardness, and dimensional requirements after processing.
Explore Material Options →Stainless SteelCorrosion-resistant fittings and hardware.
303, 304, 316, and 17-4 PH cover different machining, strength, and corrosion needs. Select the exact grade and condition for fasteners, housings, fittings, and exposed assemblies.
Explore Material Options →Copper AlloysElectrical, thermal, and bearing functions.
Copper, brass, and bronze are considered for contacts, busbars, bearings, and selected gears. Match alloy, conductivity, wear behavior, and mating conditions to the assembly.
Explore Material Options →Engineering PlasticsLow-friction, insulating, and lightweight parts.
POM, nylon, PEEK, ABS, and PE suit selected guides, gears, insulators, and covers. Review resin grade, filler, creep, moisture conditioning, temperature, and chemical exposure.
Explore Material Options →TitaniumSpecialized weight-sensitive hardware.
Selected titanium grades can suit links, fasteners, and other specified components. Review stiffness, strength, environment, machining cost, and the actual material condition.
Explore Material Options →Surface Finishing Options
Anodizing & Hard Anodizing
For compatible aluminum parts; define thickness, masking, wear faces, and post-finish dimensions.
Passivation & Electropolishing
For specified stainless-steel parts, with surface removal, cleaning, and acceptance requirements reviewed.
Plating & Conversion Treatments
Nickel or zinc plating, black oxide, and phosphate are selected for suitable materials and service conditions.
Laser Marking
Define identification, orientation marks, location, contrast, and any traceability requirements.
Define coating thickness, masking, cosmetic areas, and post-finish dimensions before quotation.
Quality Controls for Reliable Robot-Part Sourcing
Define drawing revision, material traceability, first-article needs, inspection records, packing, and delivery requirements before order release.
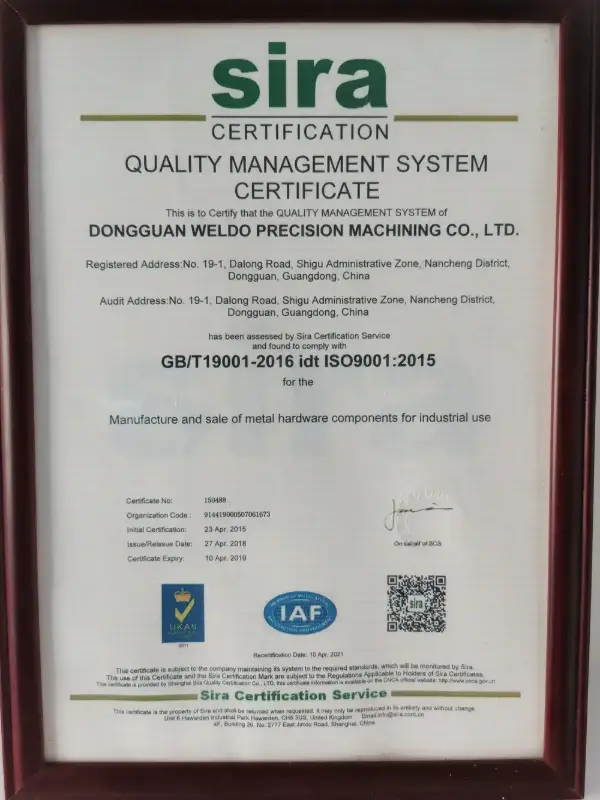
ISO 9001 Quality System
Drawing and revision control, documented production, and calibrated inspection procedures support consistent sourcing.
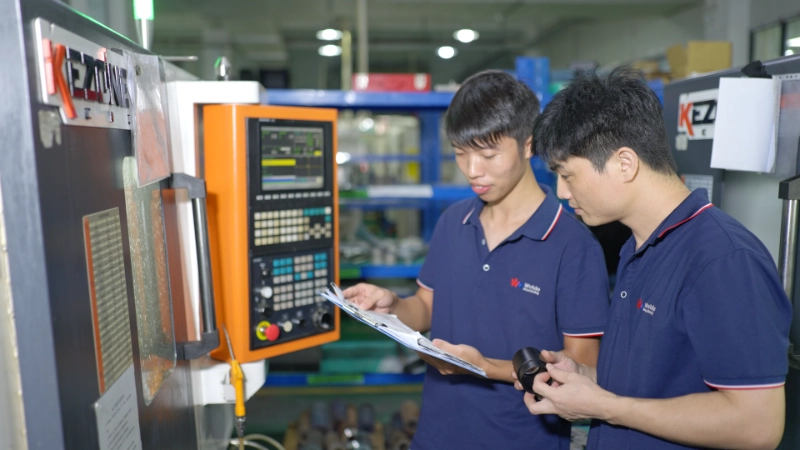
Project Quality Records
Agree dimensional reports, material certificates, first-article requirements, and finish records before production.
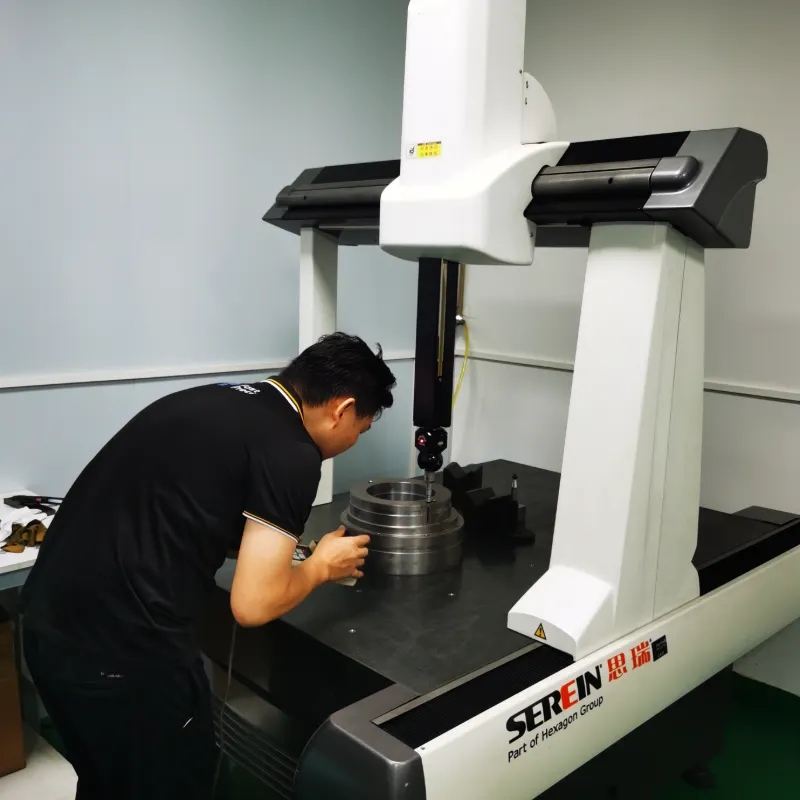
Manufacturing & Release Control
Check critical features with suitable measuring equipment, complete final review, and protect parts for delivery.
Robotics Machining Questions
Plan critical interfaces, material choices, drawing changes, and inspection before quotation.
What should I send for a robotics-part quotation?
Send the model, dimensioned drawing, revision, material, quantity, finish, and required inspection records. Identify bearing fits, motion datums, cosmetic surfaces, and the intended operating conditions.
How are motor, bearing, and gearbox interfaces controlled?
Functional datums are defined from the assembly requirements. Pilots, bores, bolt patterns, and mounting faces are machined and inspected to the drawing’s specified relationships.
Can drawing changes be supported between prototype and production?
Each approved revision is controlled separately. Changes to features, fixtures, tooling, inspection, and any existing inventory are reviewed before release.
Which materials suit lightweight robotic structures?
Aluminum is a common starting point, but stiffness, load, fatigue, thermal conditions, corrosion, and cost govern selection. Titanium or other specified materials may suit specialized requirements after engineering review.
How are tolerances selected for motion-critical components?
Define critical fits, datum relationships, and surface requirements on the drawing. Capability is reviewed by feature, considering material, size, geometry, setups, and measurement access rather than applying one tight tolerance to the whole part.
How are delivery risks or nonconforming parts handled?
Delivery risks are communicated for review of a recovery plan. Affected parts are contained and investigated, with rework, replacement, or another customer-approved disposition agreed as appropriate.